Technical article
Designing a deterministic RS-485 multi-node protocol
29 July 2026 · Shakil Tanvir
Notes on the master-slave broadcast scheme behind the EOD ROV — and why it won Best Technical Presentation at ICCIT 2024.
Why a custom RS-485 protocol?
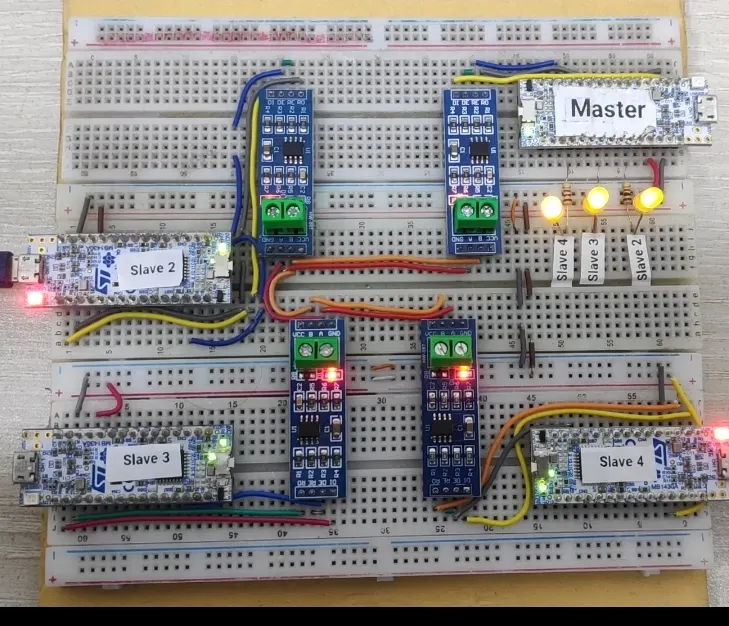
When we built the EOD ROV for the defence client, off-the-shelf buses couldn't give us deterministic timing across motors, sensors, and the robotic arm at once. So we designed a master-slave broadcast protocol on the RS-485 physical layer.
- Deterministic polling windows per node
- CRC-checked broadcast frames
- Graceful degradation when a node drops
This work became our Best Technical Presentation at ICCIT 2024. In these notes I'll unpack the design decisions and what I'd do differently next time.